A five-digit AmazingHand
My fork of Pollen Robotics' open-source robot hand. It adds a pinky, three-segment fingers and a powered wrist.
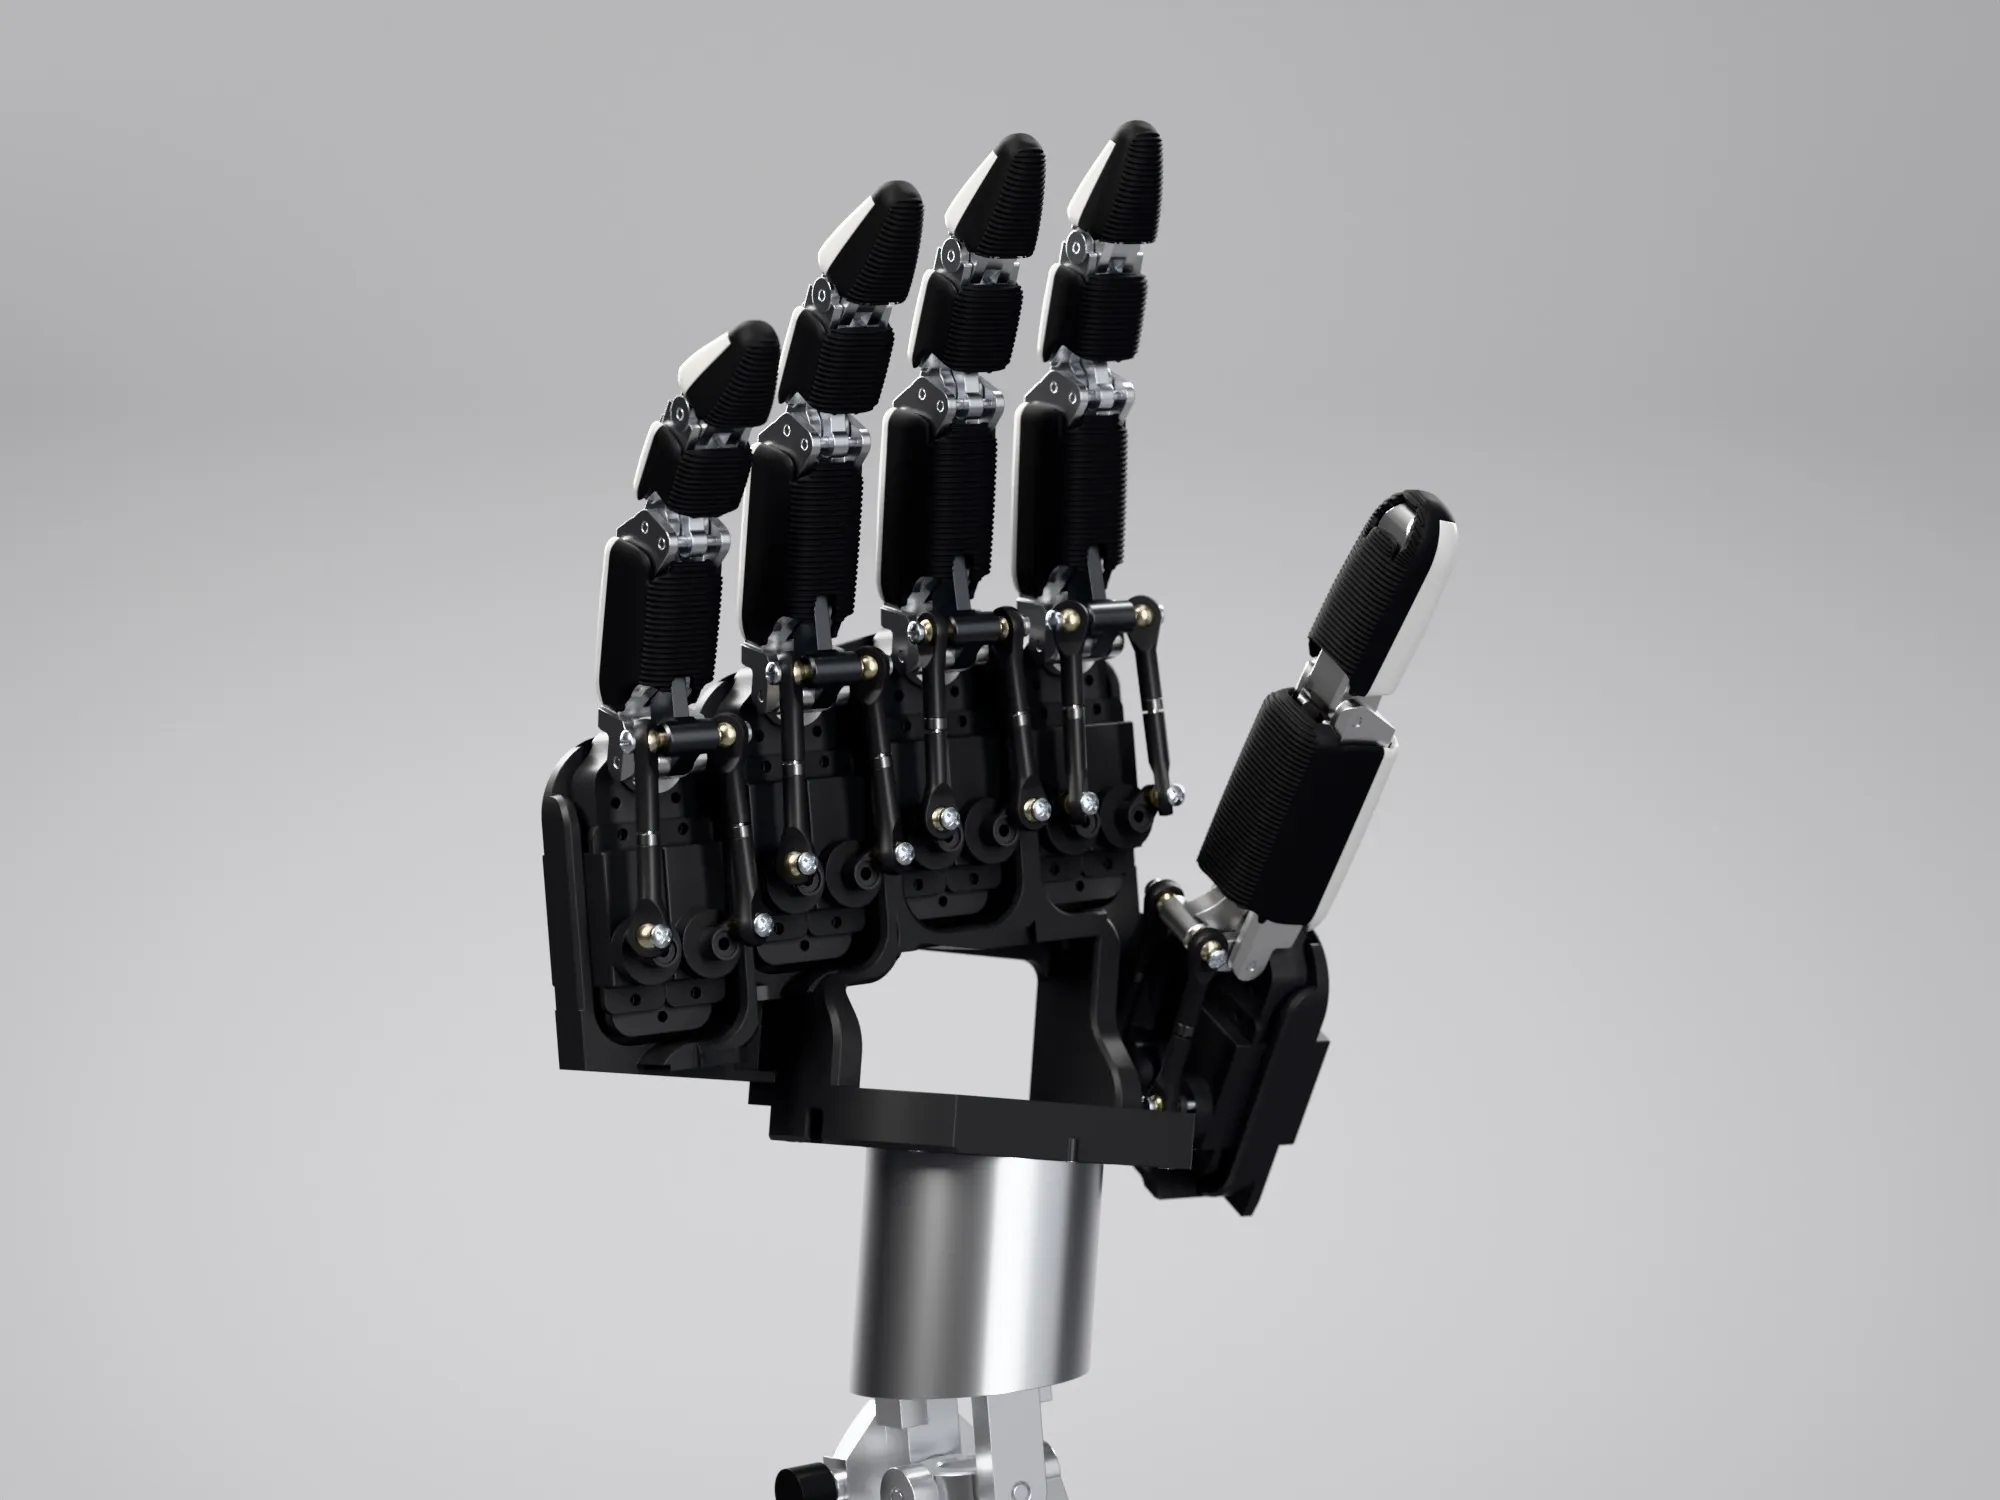
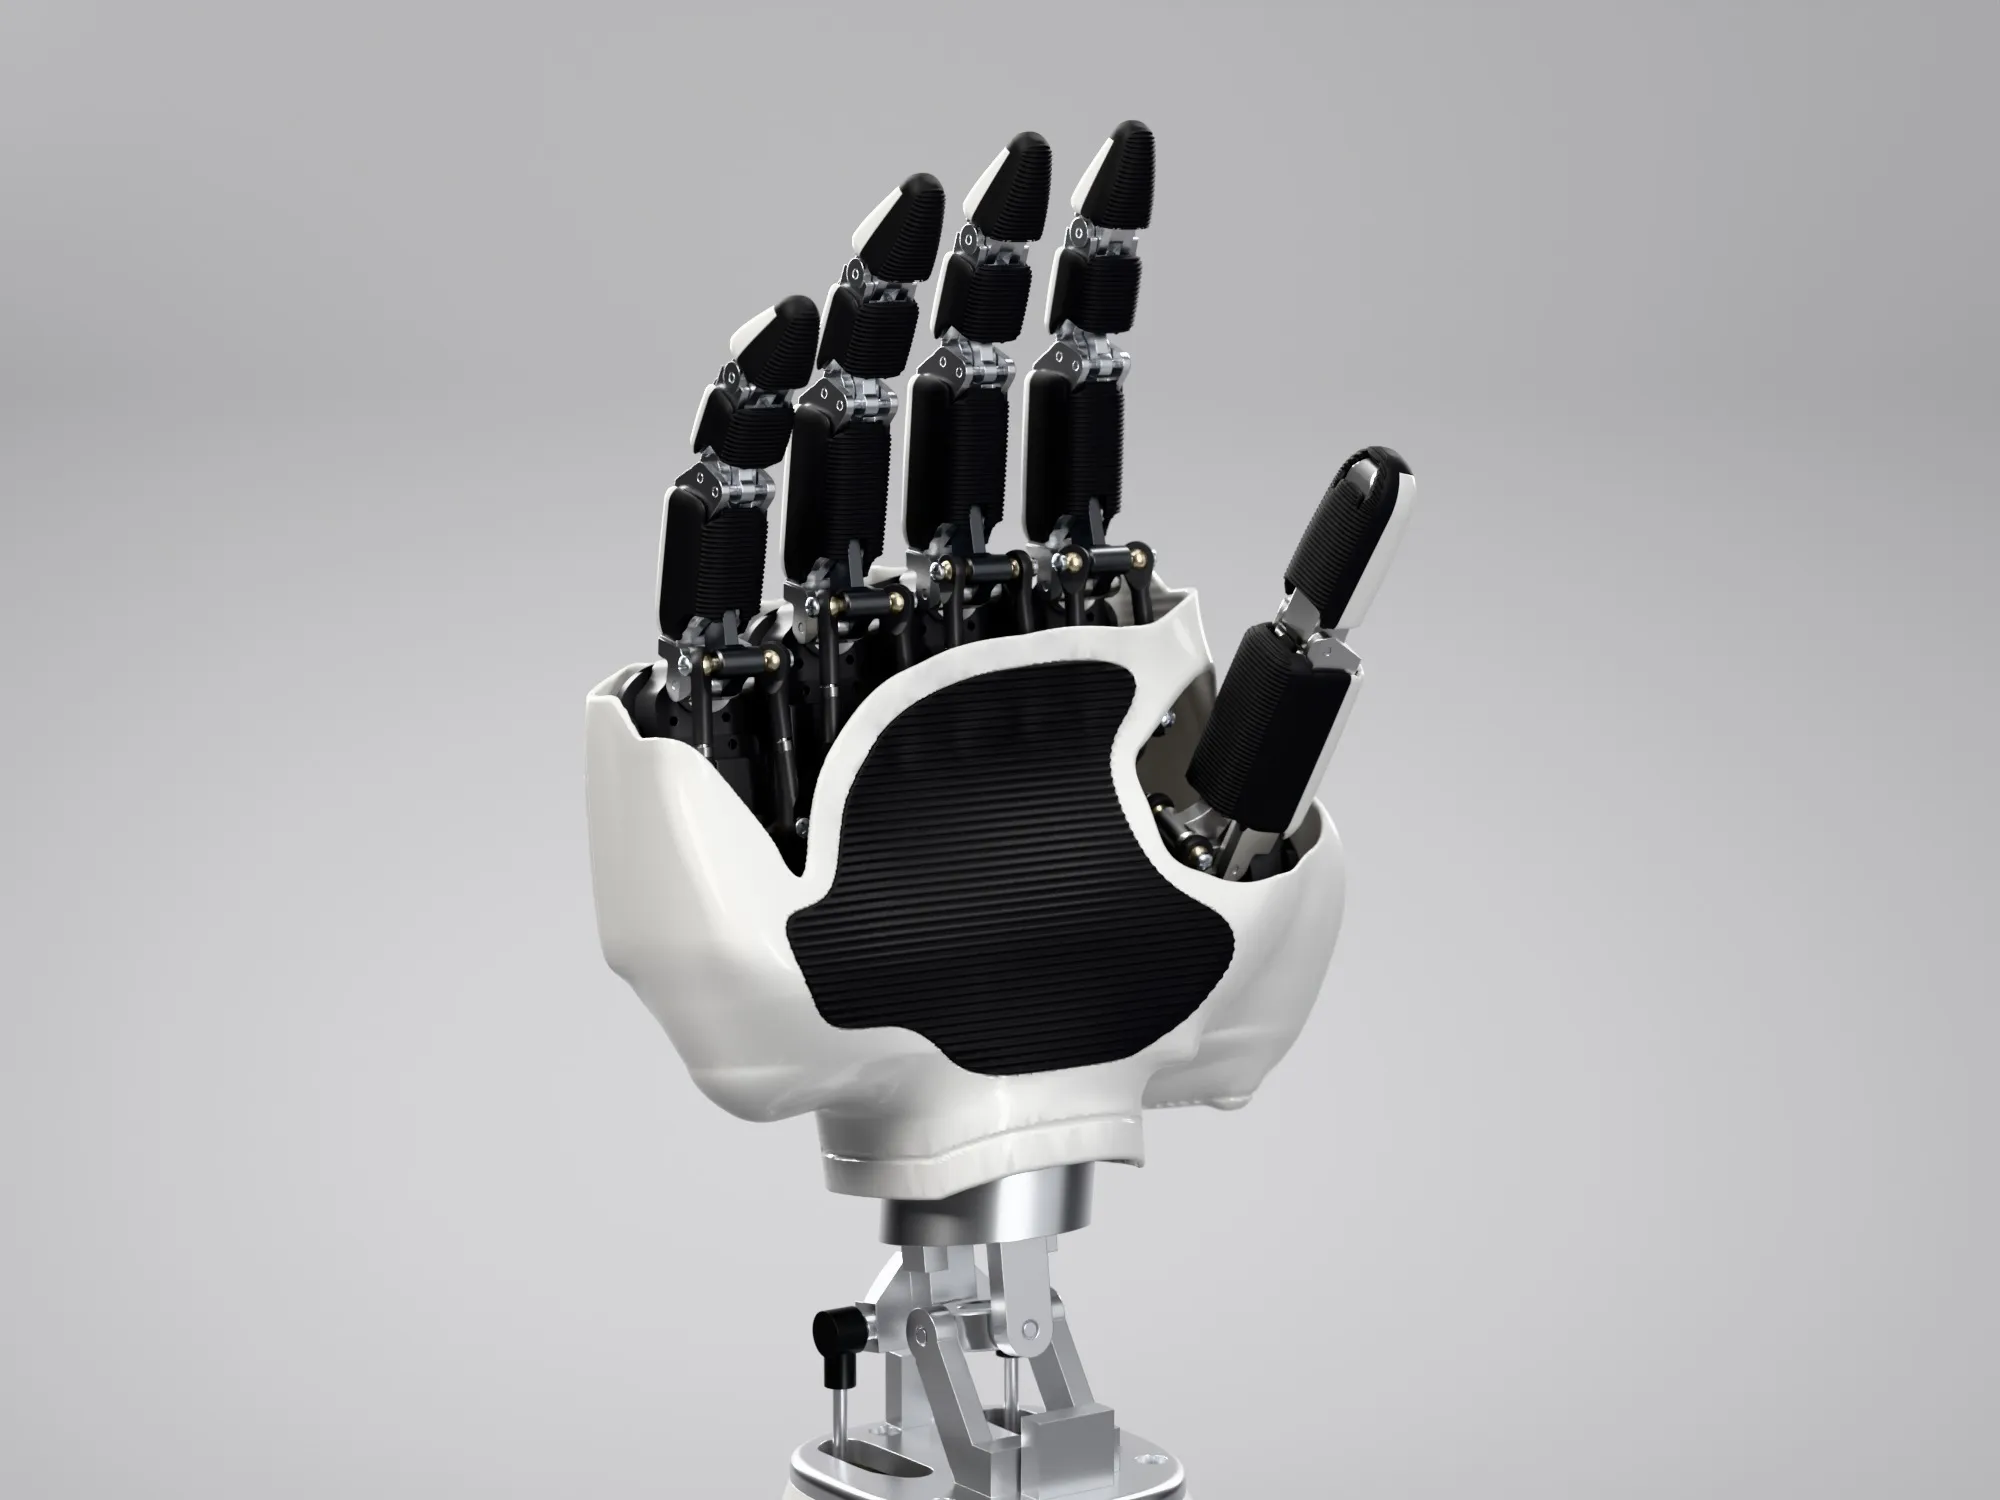
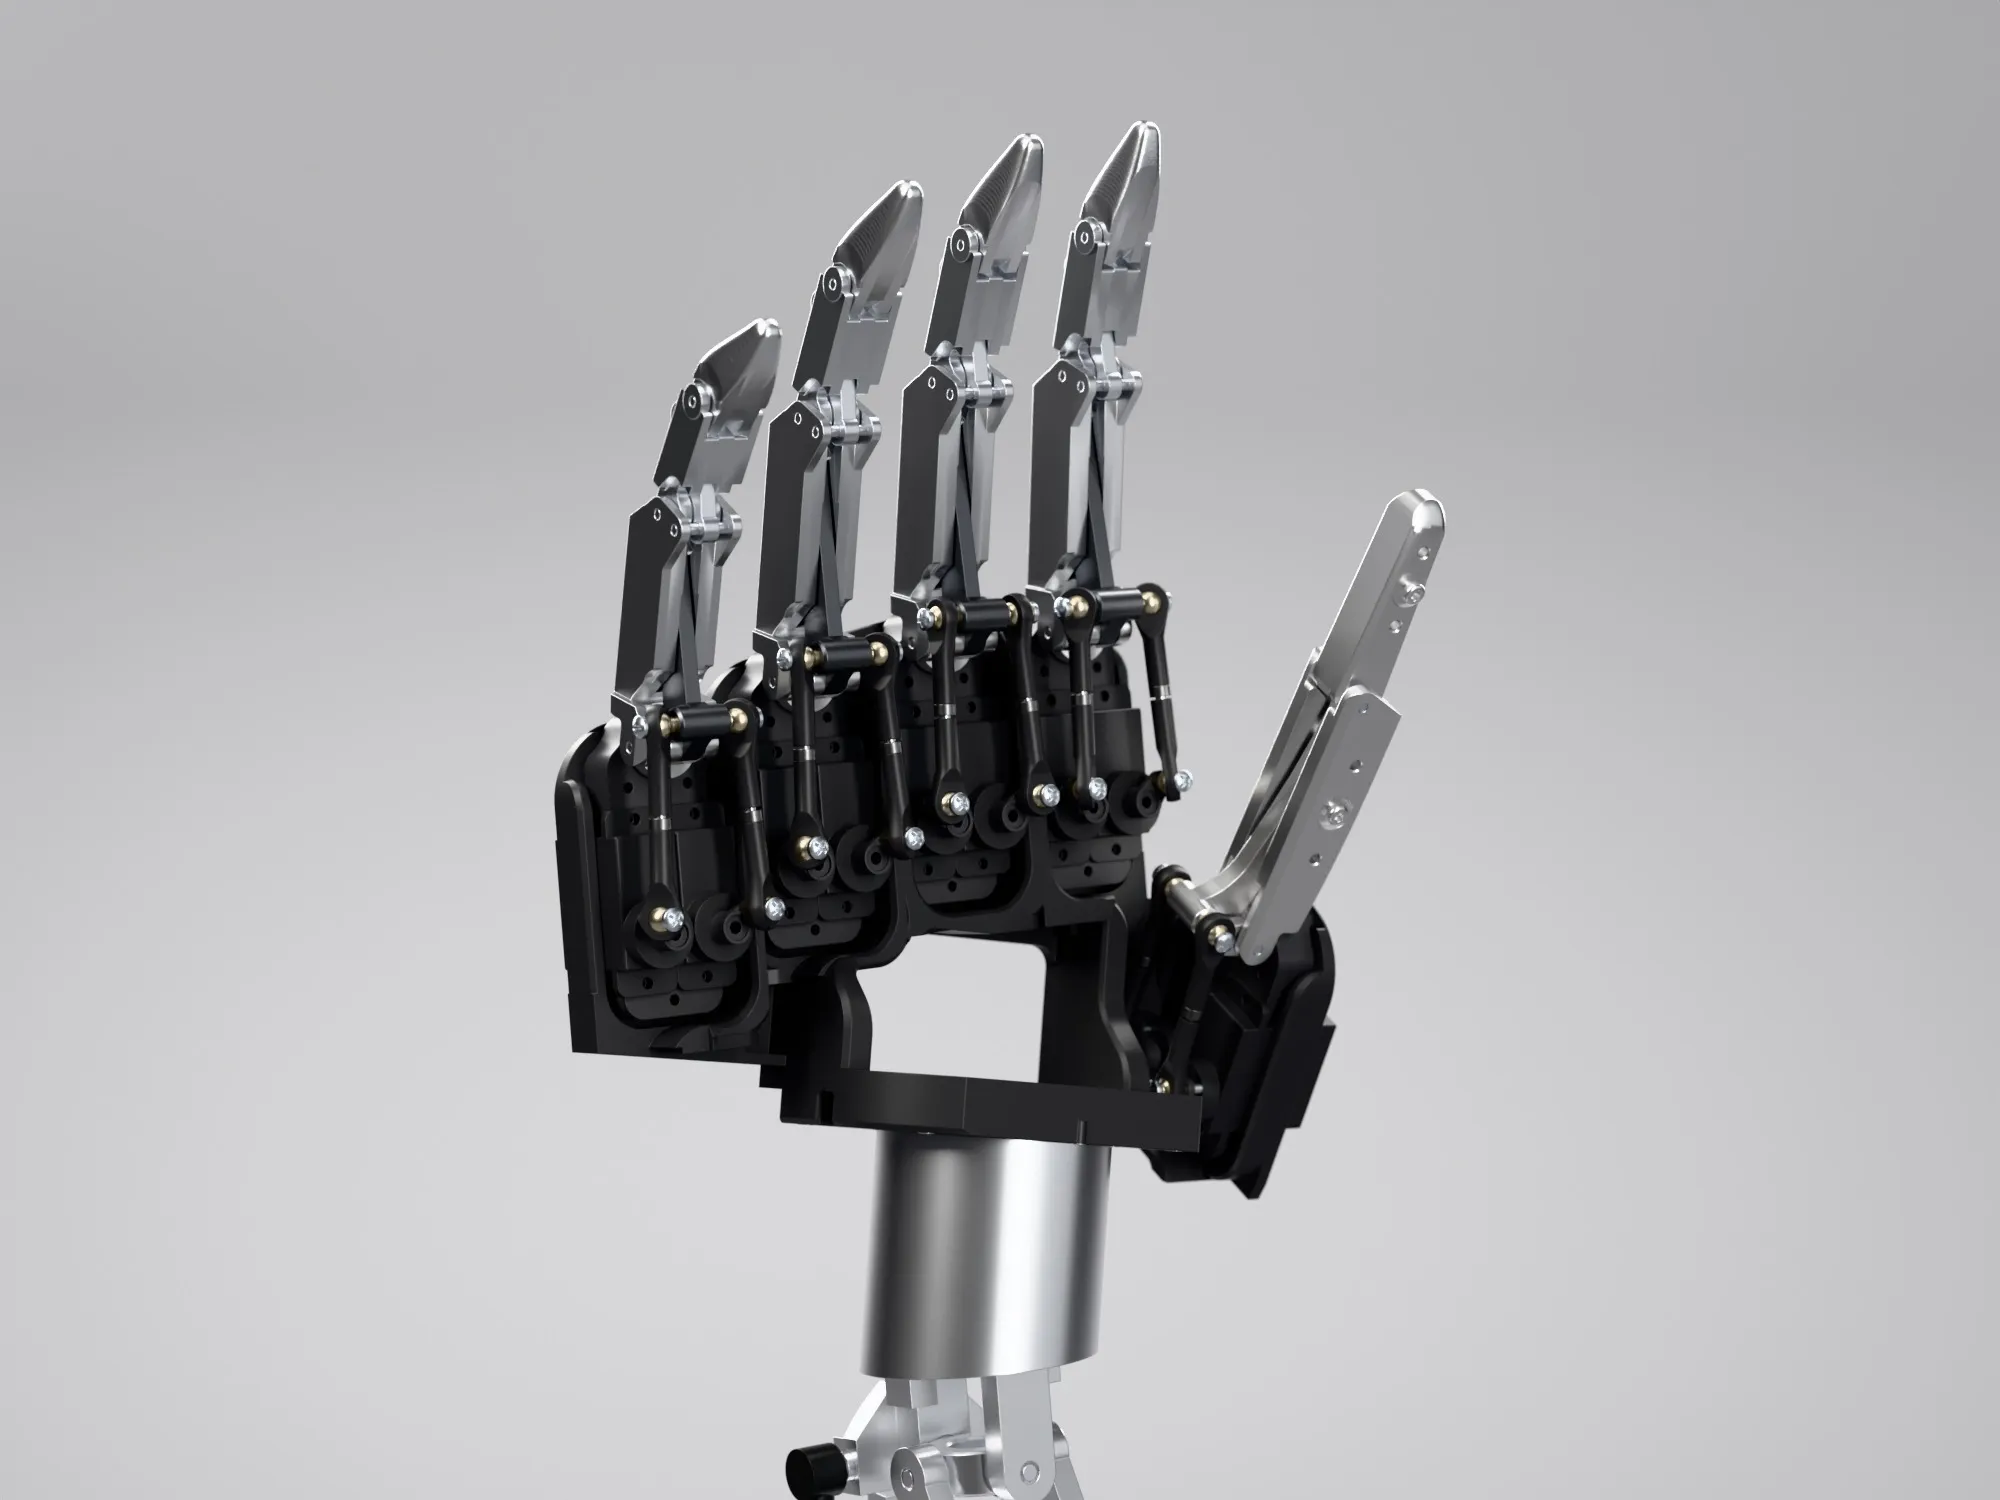
Poses
-
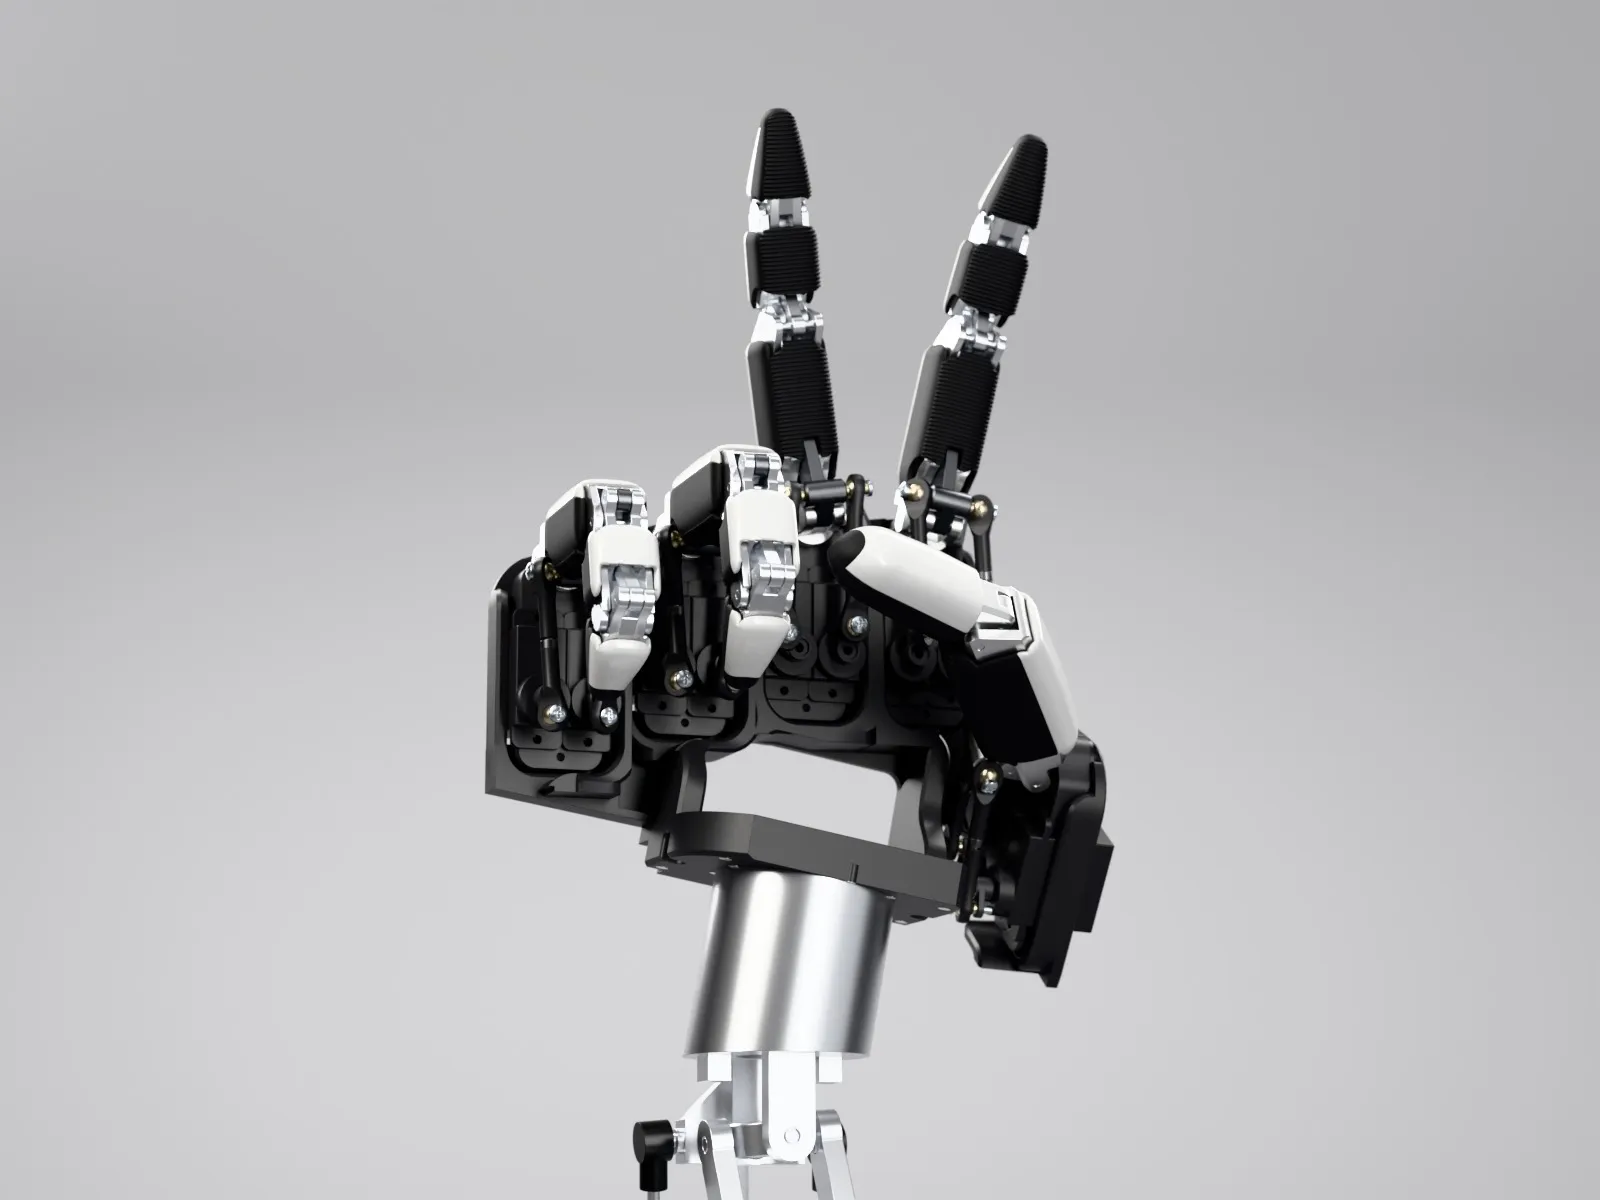
Peace -
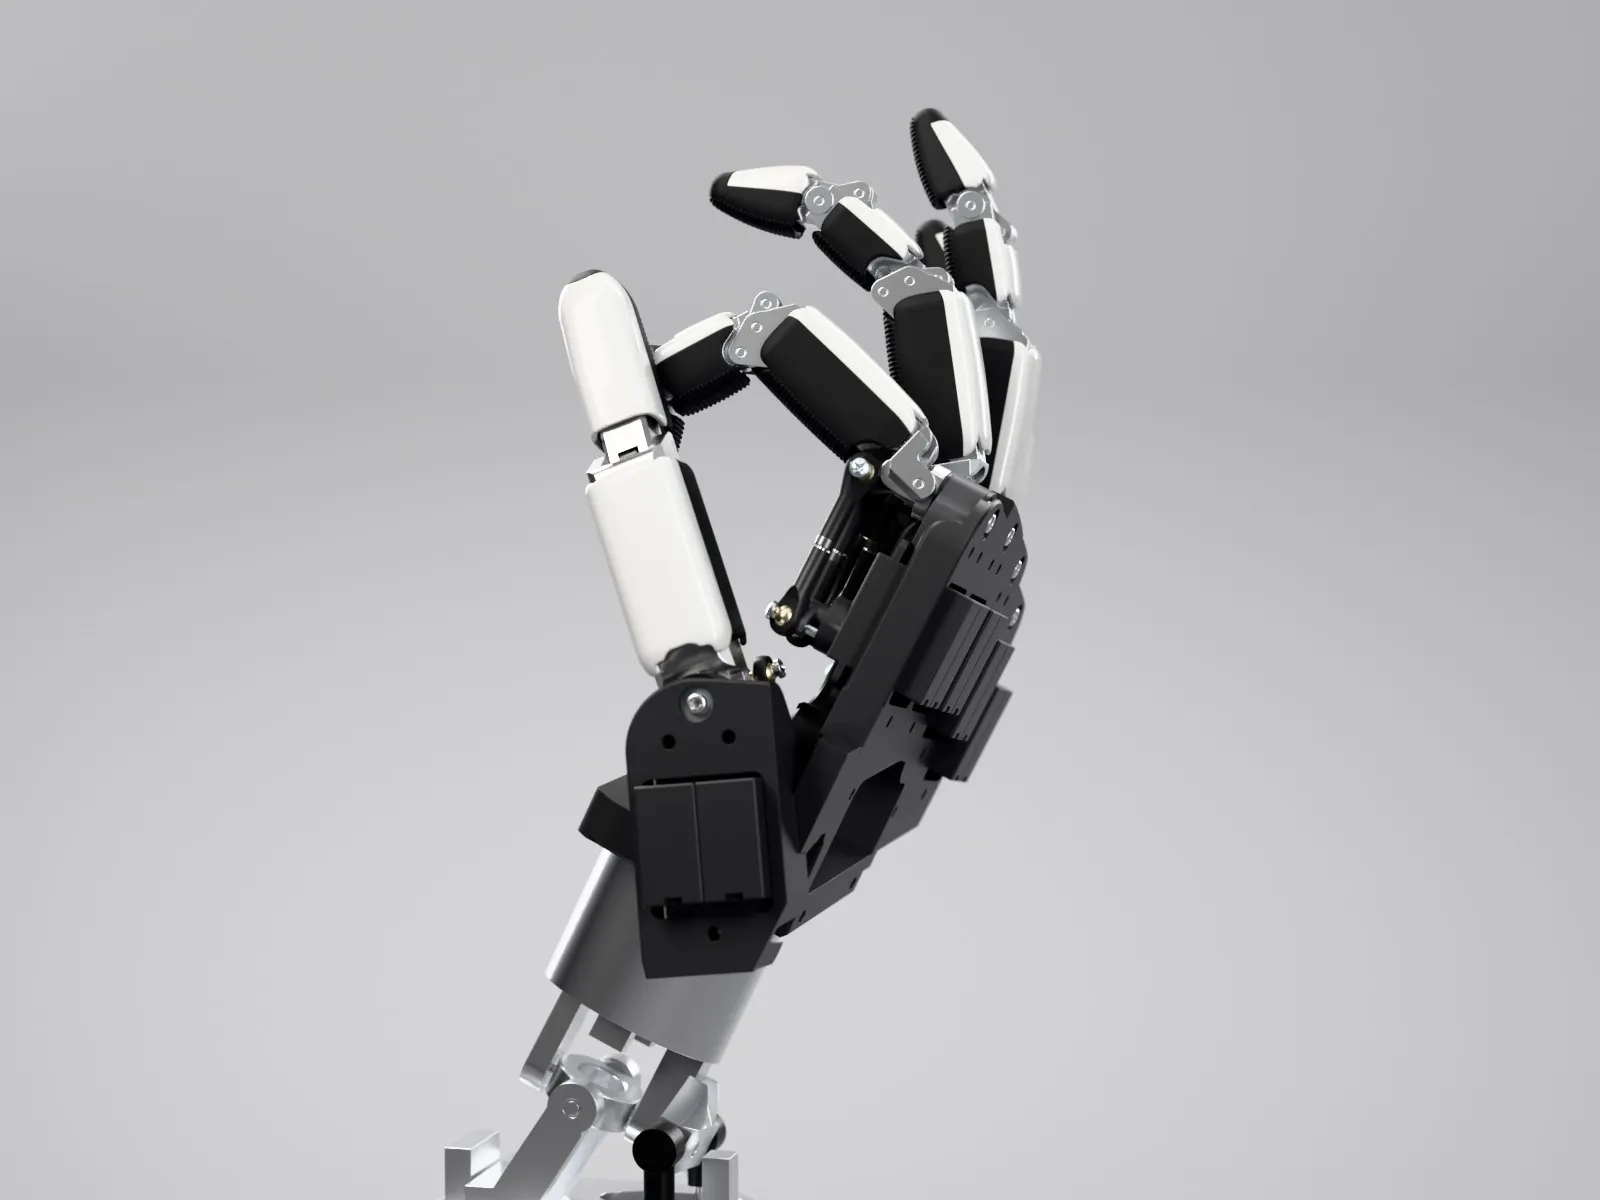
OK -
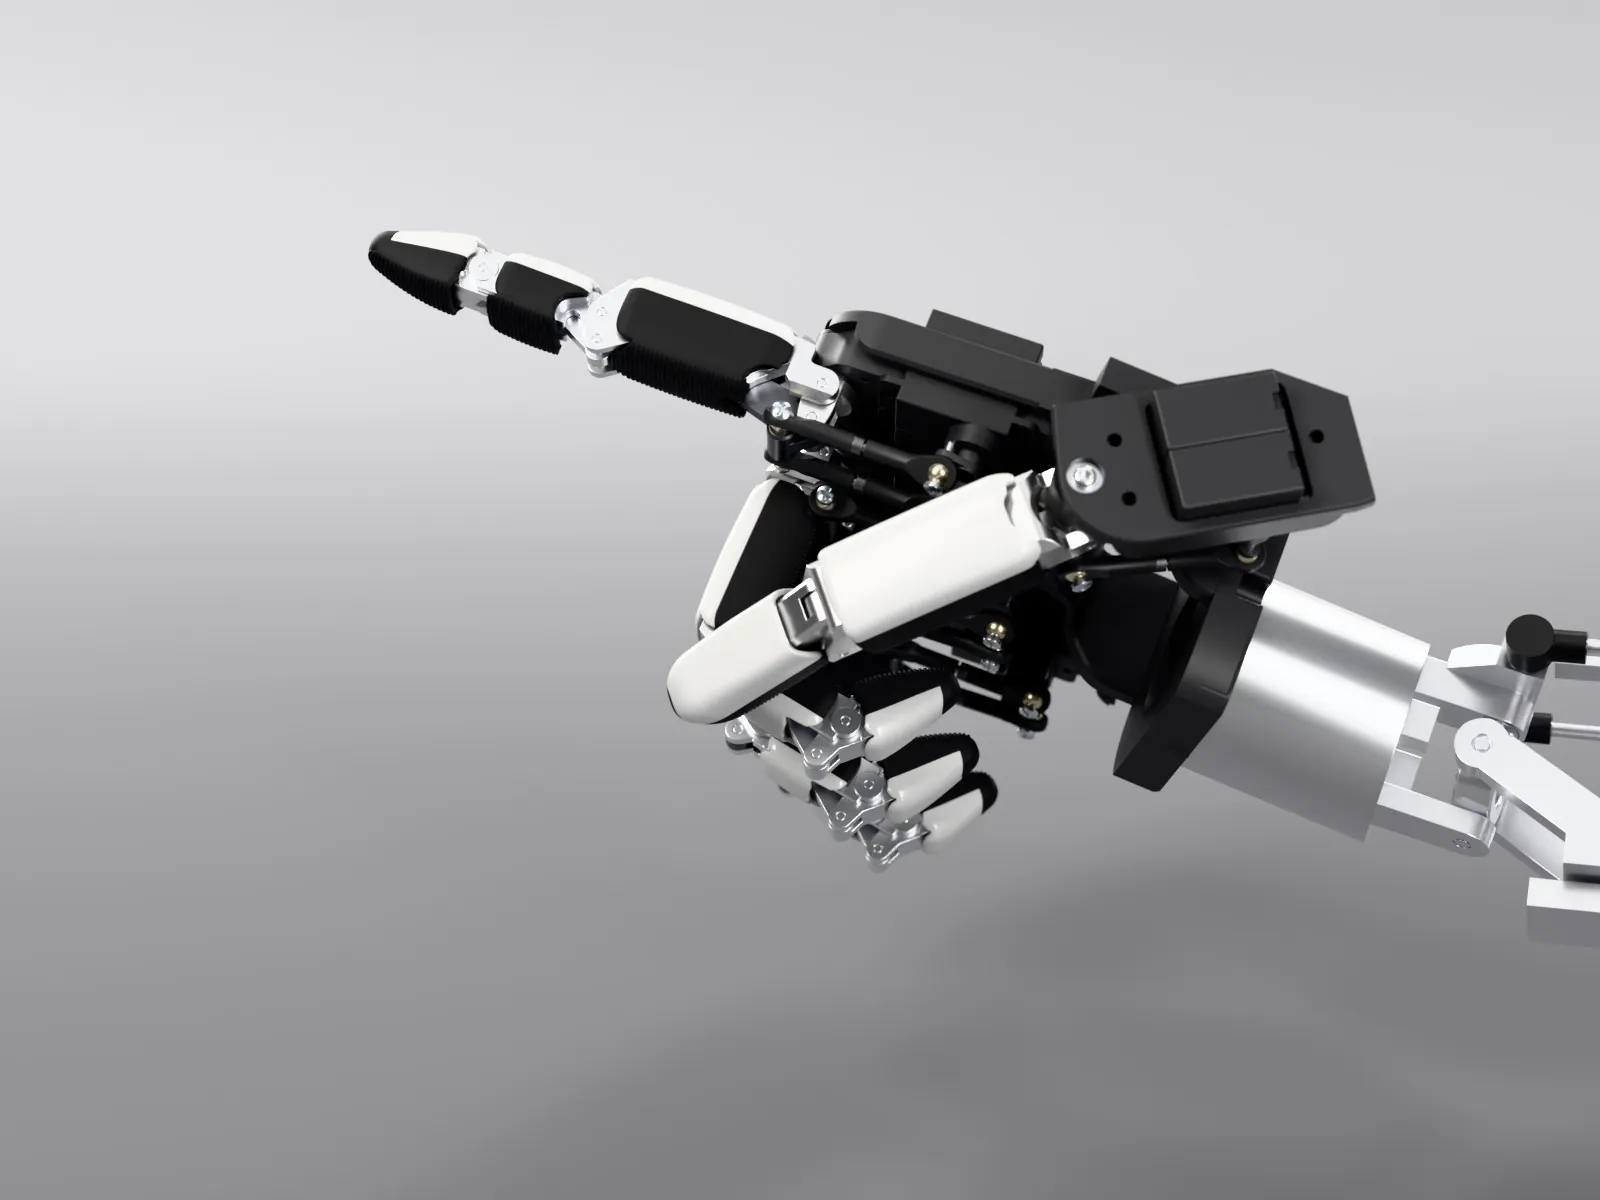
Pointing -
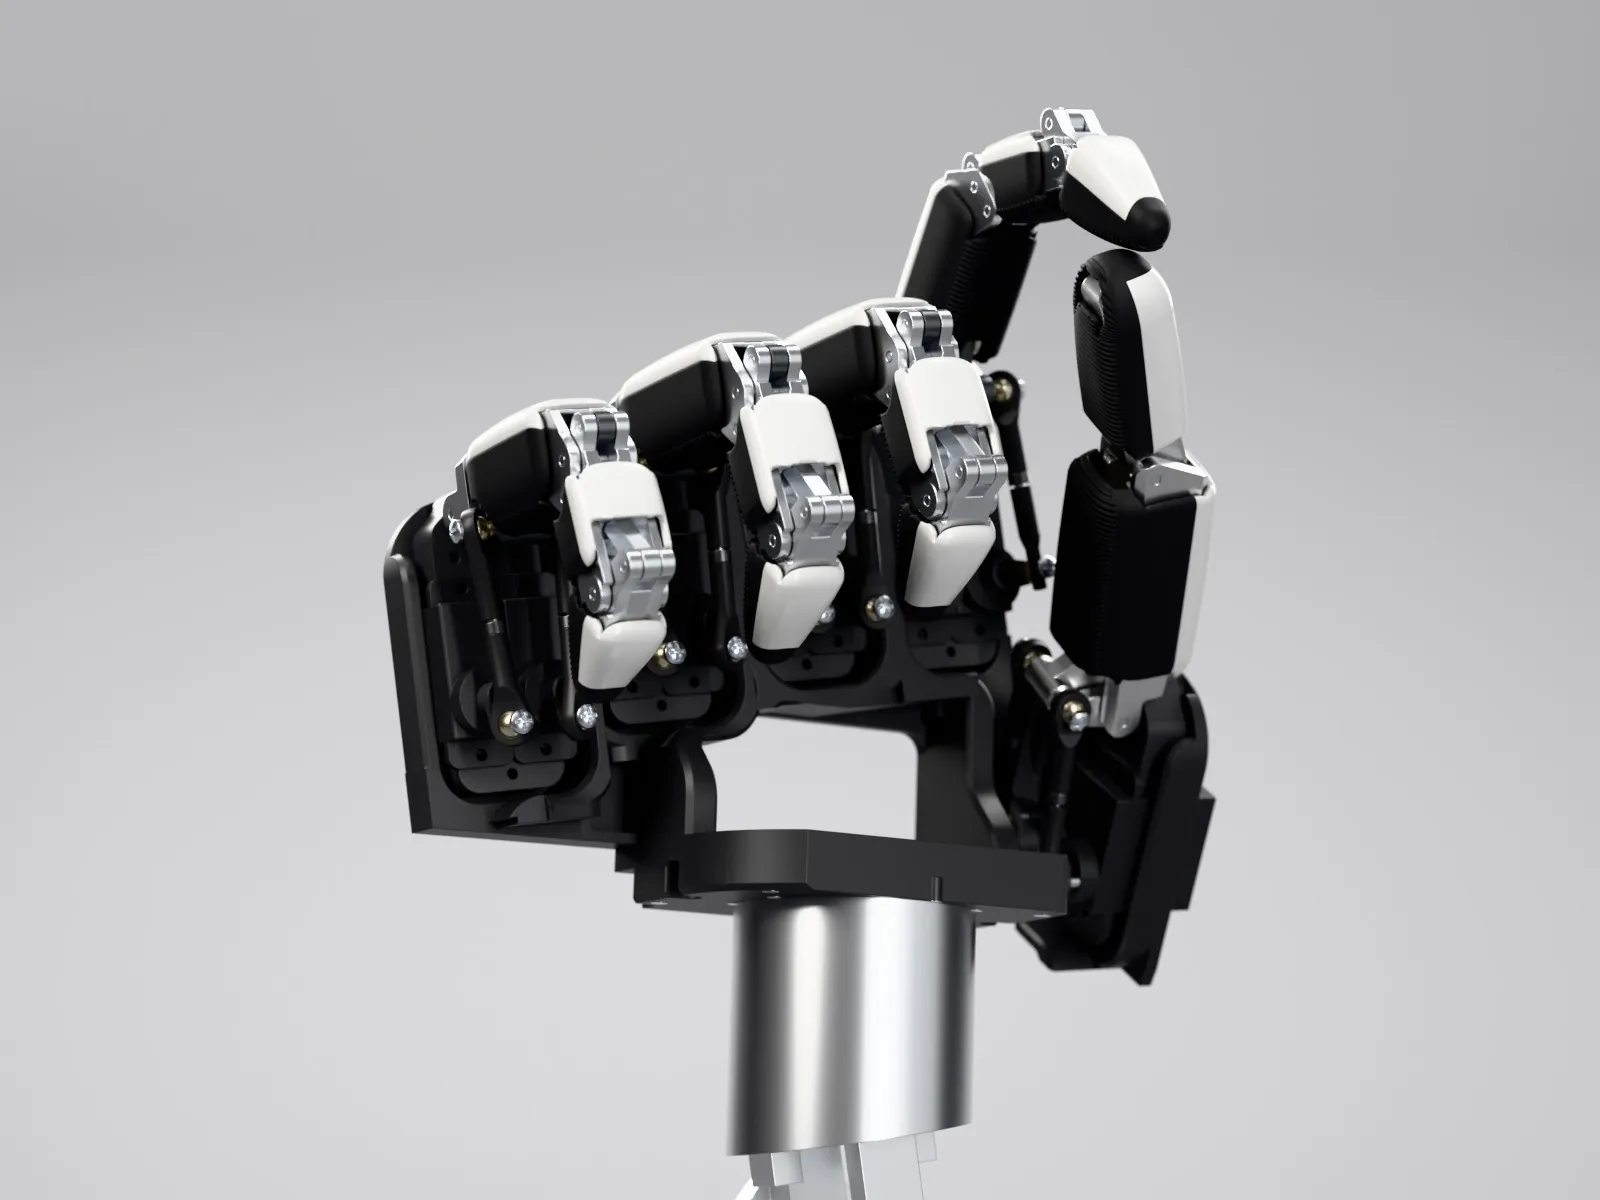
Pinch -
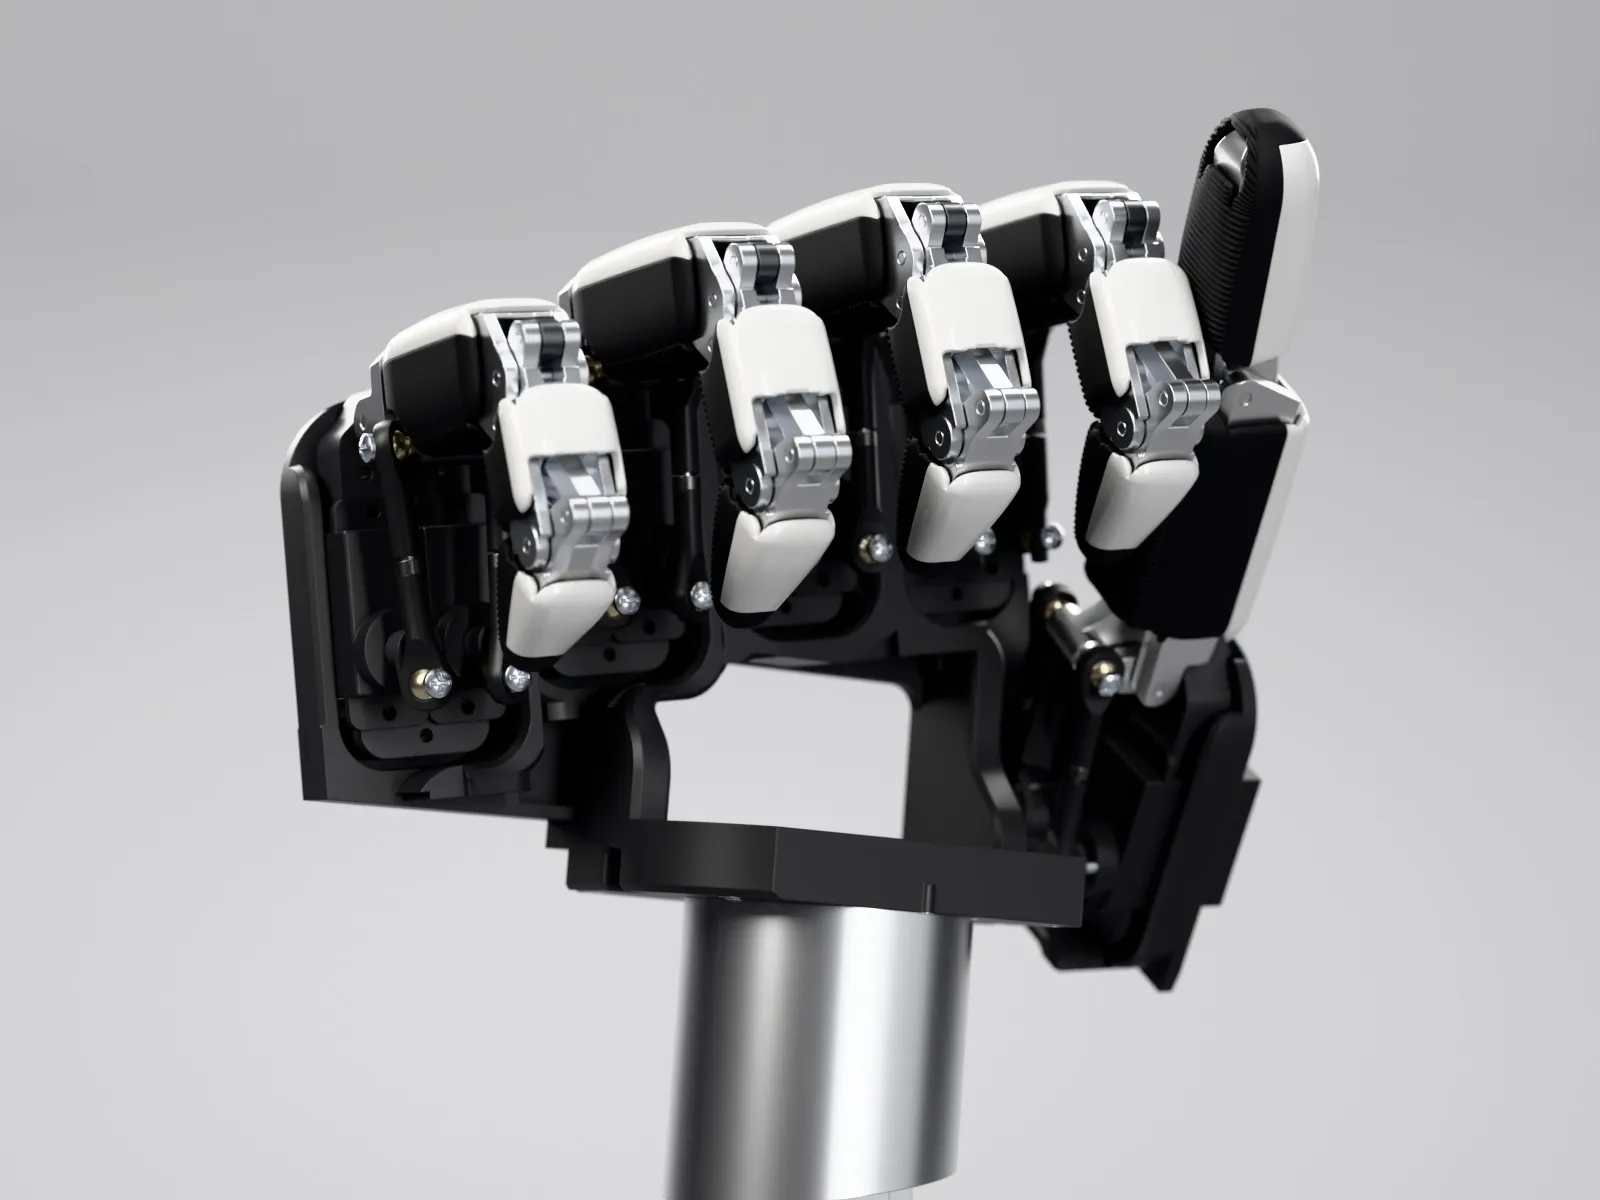
Fist -
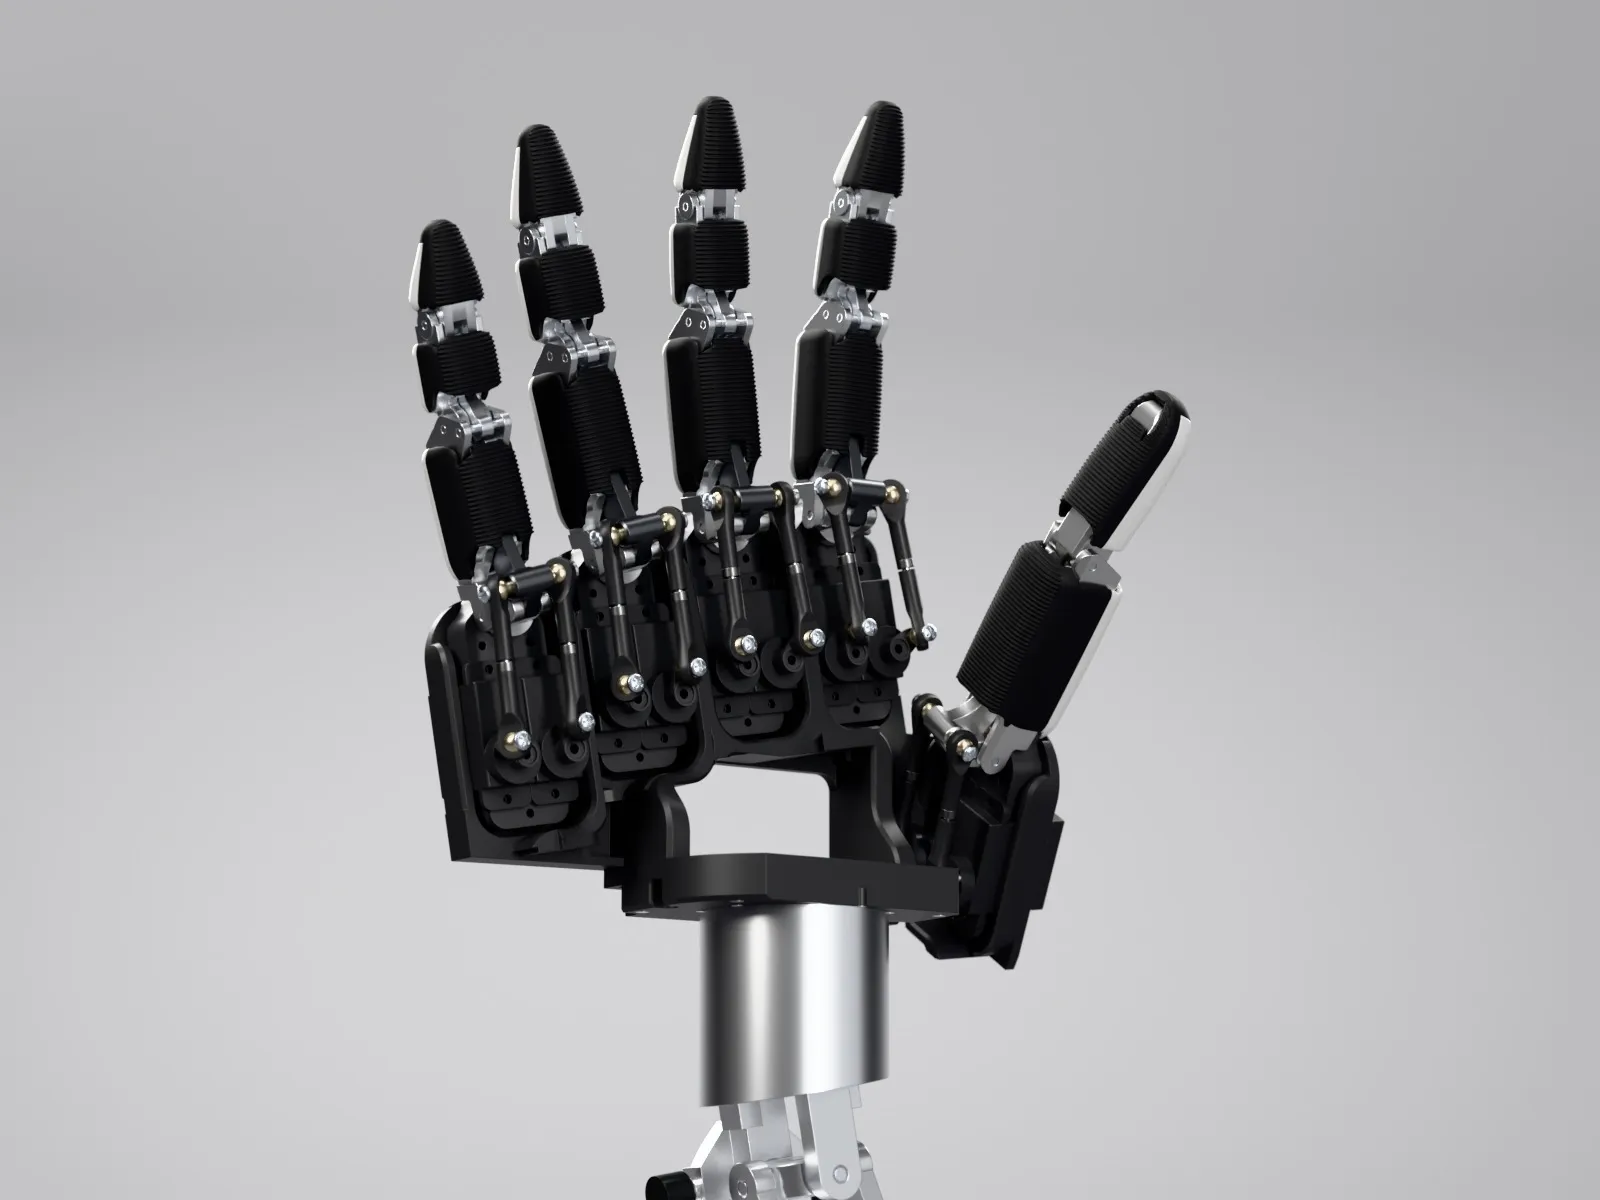
Spread
Each pose comes from the fork's pose file. The simulated hand is driven to it and left to settle, and that is what gets rendered. All are shown without the palm shell.
What the fork changes
- A fifth digit. The stock hand has three fingers and a thumb. This adds a pinky on a wider palm plate, for ten finger servos in all.
- Three segments per finger. Each finger keeps the stock two-servo drive and gains a third phalanx on a passive linkage. The joints reach 89°, 78° and 54°.
- A powered wrist. A two-axis gimbal driven by two more servos in a tapered forearm: ±60° of flexion and ±25° of deviation.
- A hand shape. Parallel fingers at a 30 mm pitch, a slimmer thumb mount, sculpted palm and back shells, and ribbed grip pads.
What exists
- CAD for every part, generated by scripts, with an assembled model of the whole hand.
- A MuJoCo model, with poses such as a pinch, a peace sign and an OK sign checked for clearance.
- Webcam teleoperation in simulation: hold a hand up to the camera and the simulated hand follows.
- Control code for the real servos, with a dry-run mode.
- An all-printed mock-up, with printed stand-ins for every bought part, for checking the assembly before buying servos.
What is still open
The design notes list it: printing and load-testing the final fingers, simulating grasps, and a left hand with the final fingers.
Credit
AmazingHand is by Pollen Robotics. Its code is under Apache 2.0 and its mechanical design under CC BY 4.0, and this fork keeps both.